FMM-L: the mission module that keeps your vehicle connected and on track.
A resilient command link and GNSS integrity monitor for any ArduPilot or PX4 platform.
FMM-L v1
What it does
FMM-L v1 does exactly four things. Nothing more is claimed and nothing more is built in yet.
Capability
What It Does
Encrypted C2 Link
Command and telemetry travel over an AES-128 encrypted channel between operator and vehicle.
Relay / Mesh
FMM-L modules forward each other's traffic, extending the link's range without added ground infrastructure.
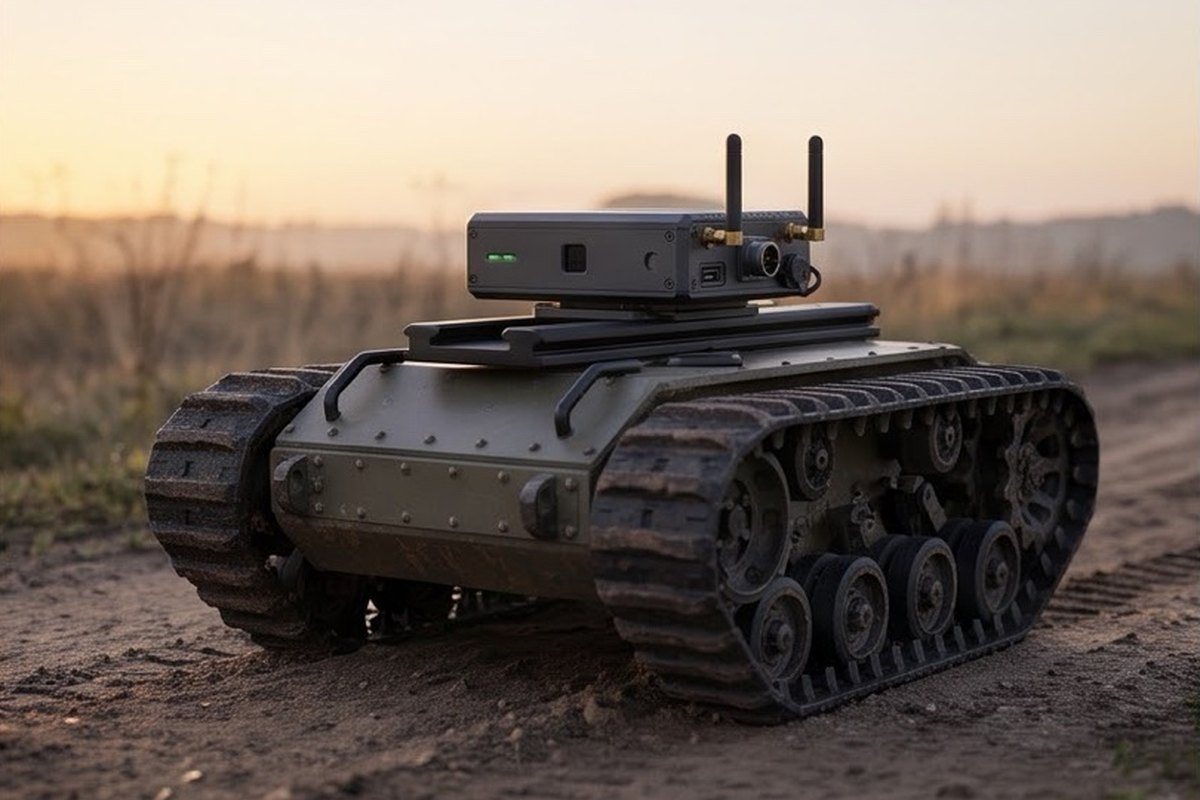
Vehicle-Agnostic
Works with any ArduPilot or PX4 autopilot over MAVLink — no integration work on the customer's side.
GNSS Integrity Monitoring
Detects GPS jamming and spoofing and alerts the operator in real time.
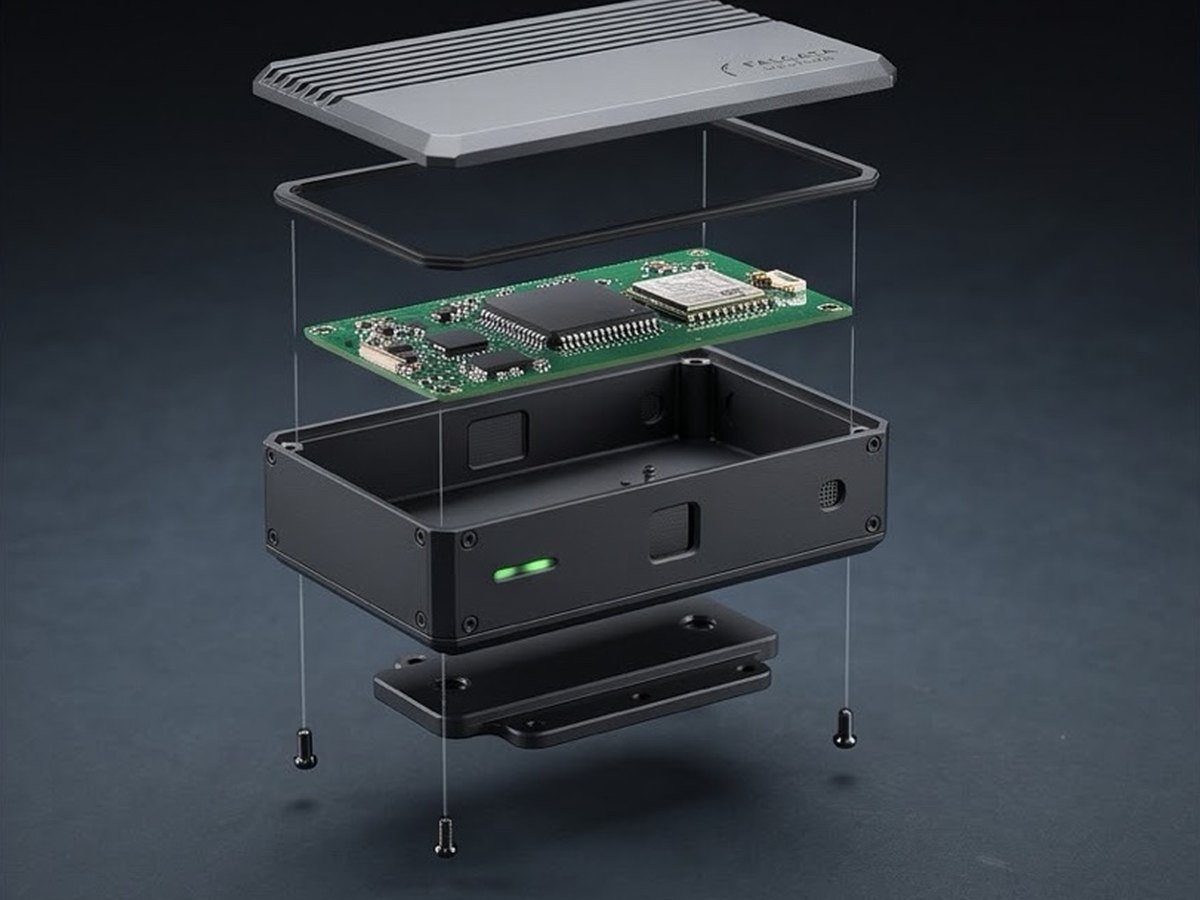
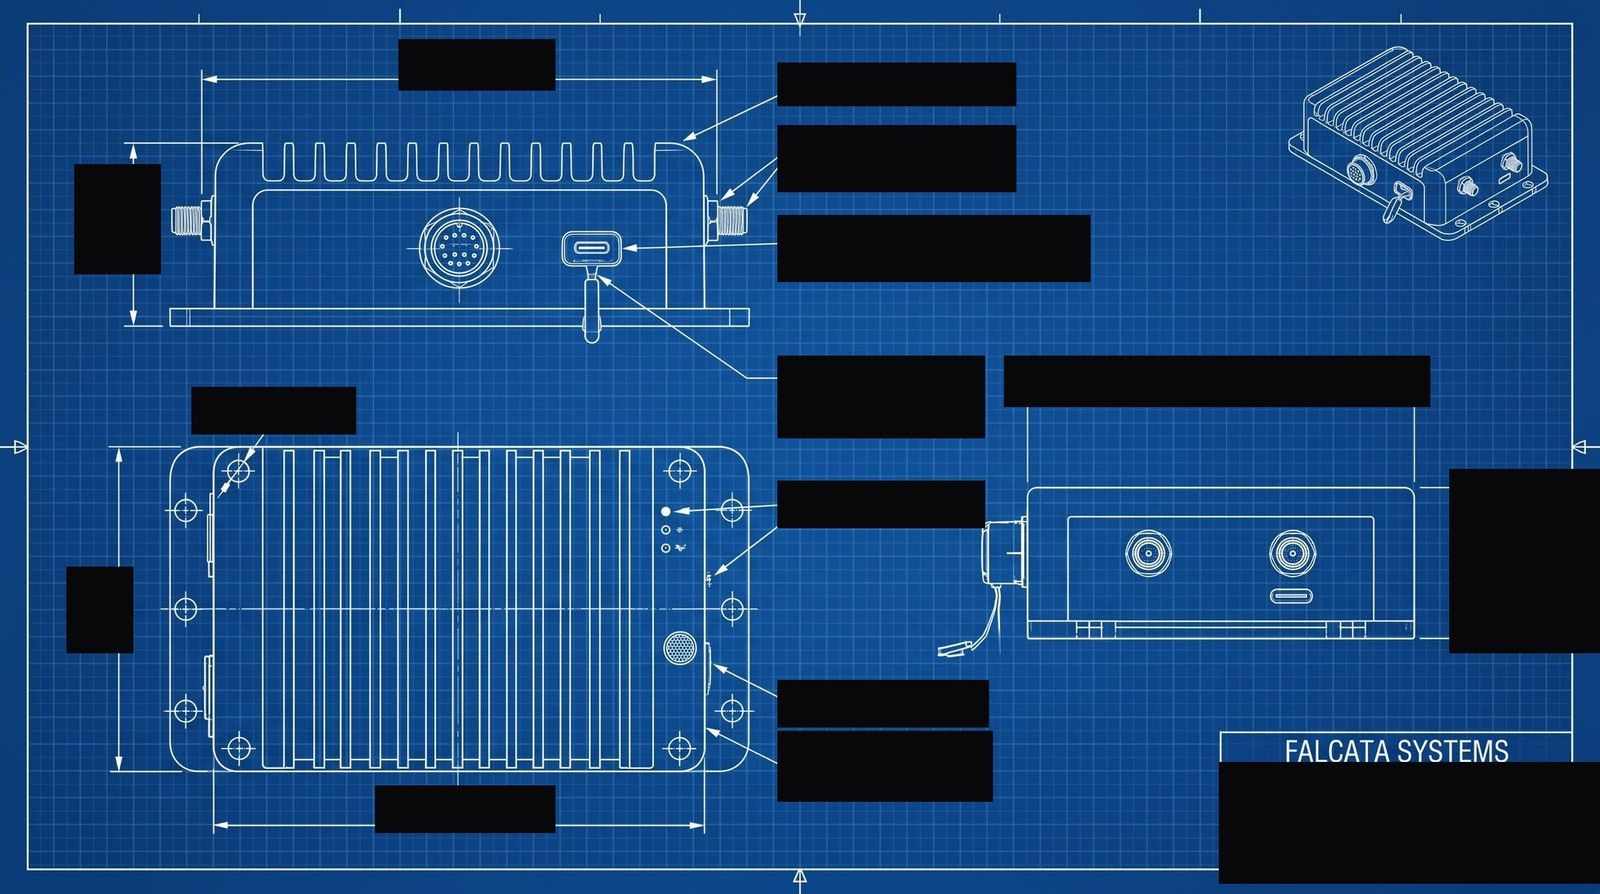
Concept renderFMM-L, exploded view.Concept renderFMM-L, technical blueprint. Dimensions and connector details redacted for publication.
Concept renderFMM-L mounted on a ground vehicle — vehicle-agnostic by design. Placeholder image, real render pending.
What It Is — And Isn't
Complements your video link. Doesn't replace it.
FMM-L is a resilient command-and-control channel plus a GNSS integrity monitor — not a video datalink. It carries no video and makes no claim to high bandwidth. It complements whatever video or sensor link the vehicle already carries. We don't call it "unjammable"; what we build is a link designed to keep working under jamming, and a monitor that tells the operator when the GPS fix can't be trusted.
Differentiators
Why FMM-L is built this way
European-Built
Designed and assembled in Portugal, with components sourced from the EU and NATO member states.
Low Cost per Node
Priced to fit cheap, attritable vehicles — not just expensive ones that can absorb a high-cost payload.
Native MAVLink
Speaks MAVLink natively to ArduPilot and PX4, so there's no custom integration layer to build or maintain.
GNSS Integrity Built In
Spoofing and jamming detection isn't an add-on — it ships in FMM-L v1, with alerts straight to the operator.
Dual-Use
Built for defense and for civil protection — wildfire response, search and rescue — not a single-market product.
How It Works
From requirement to deployment
1
Initial Consultation
Discuss the vehicle, the mission, and the operating environment.
2
Fit Check
Confirm ArduPilot/PX4 compatibility and mounting on the target platform.
3
Bench & Field Validation
Validate the link, relay, and GNSS-integrity behavior before deployment.
4
Delivery & Support
Deployment on the customer's vehicle and ongoing technical support.
Have a vehicle you want to protect?
Tell us what it is and what it needs to survive, and we'll tell you what's achievable.